sumizuke / research / gramazio kohler research / 2026
robotic fabrication, computer vision, carpentry, human-robot co-fabrication
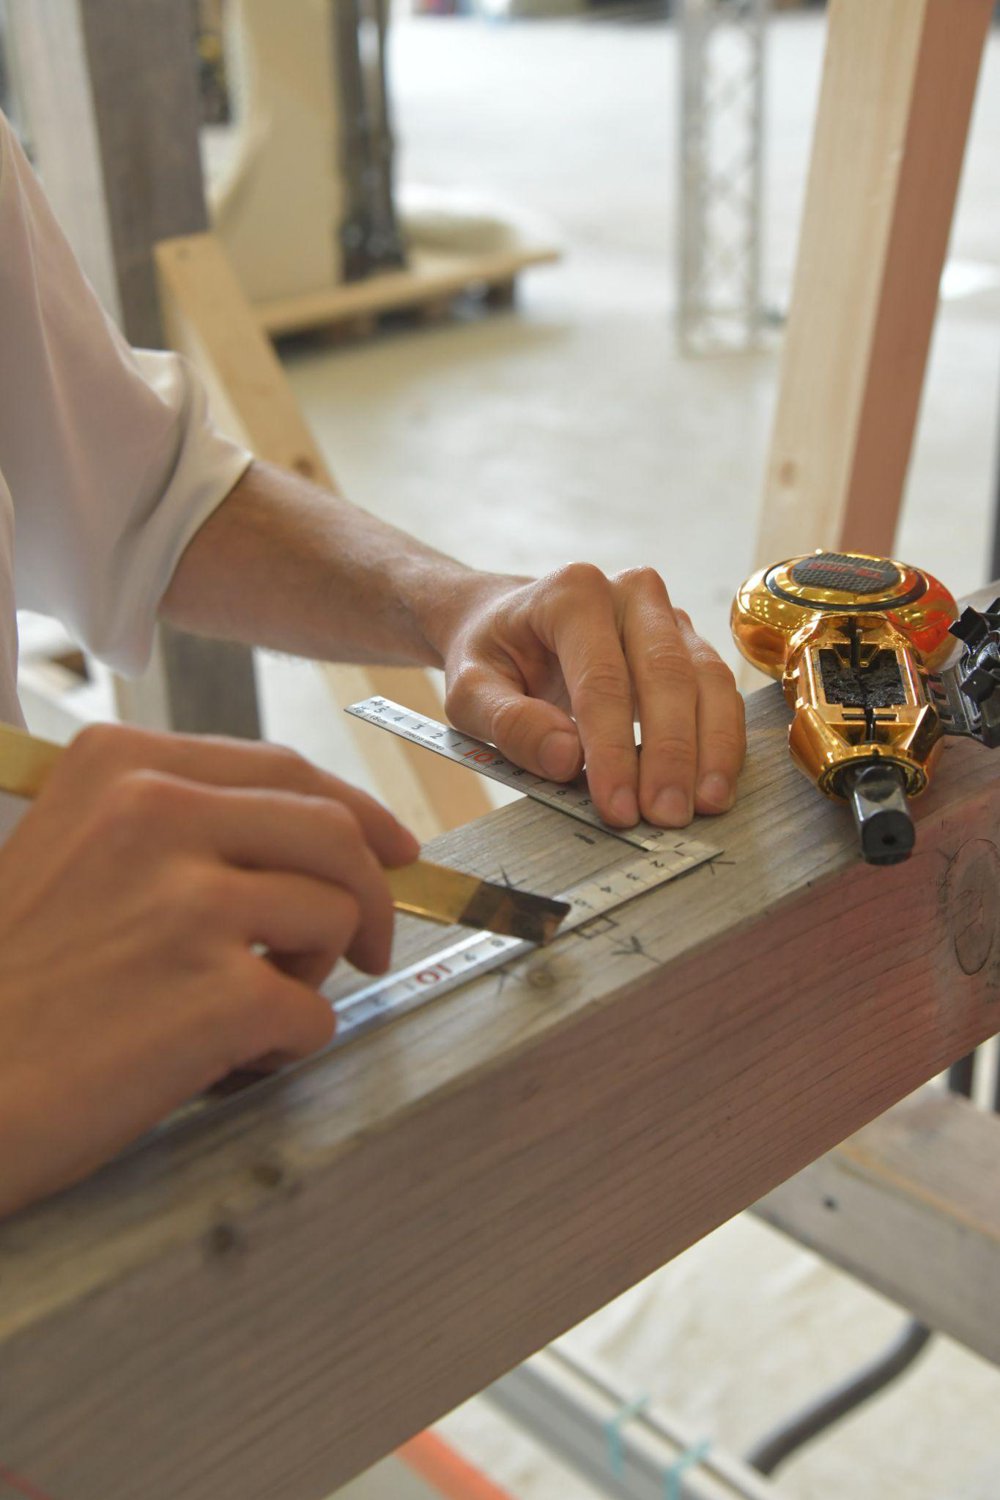
sumizuke is a robotic fabrication framework that lets carpenters instruct a robot the way they instruct
each other: with hand-drawn markings on the timber. Named after the Japanese tradition of ink markings
that guide assembly, the system reads custom symbols on timber surfaces with a deep-learning keypoint
detection model and translates them into robotic actions, without code, CAD or screen-based interfaces.
The framework was tested on an industrial KUKA KR10 and a collaborative UR10e, through localisation,
marking-defined features and on-site joinery. It reaches around ±3 mm from vision alone and
millimetric precision with robotic touch-up, offering a low-threshold, craft-native workflow for small
carpentry businesses working on renovation, retrofitting and material reuse.
Published in Construction Robotics
Kango, A.*, Barna, G. P.*, Camarsa, G. H., Laki, K., Gramazio, F., Kohler, M. (2026). Sumizuke for robotic co-crafting: hand-marking-guided robotic fabrication framework for skilled carpentry. Construction Robotics, 10(2), 40.
* equal contribution
https://doi.org/10.1007/s41693-026-00192-2
with Gergely Péter Barna
All photographs : Gramazio Kohler Research, ETH Zürich
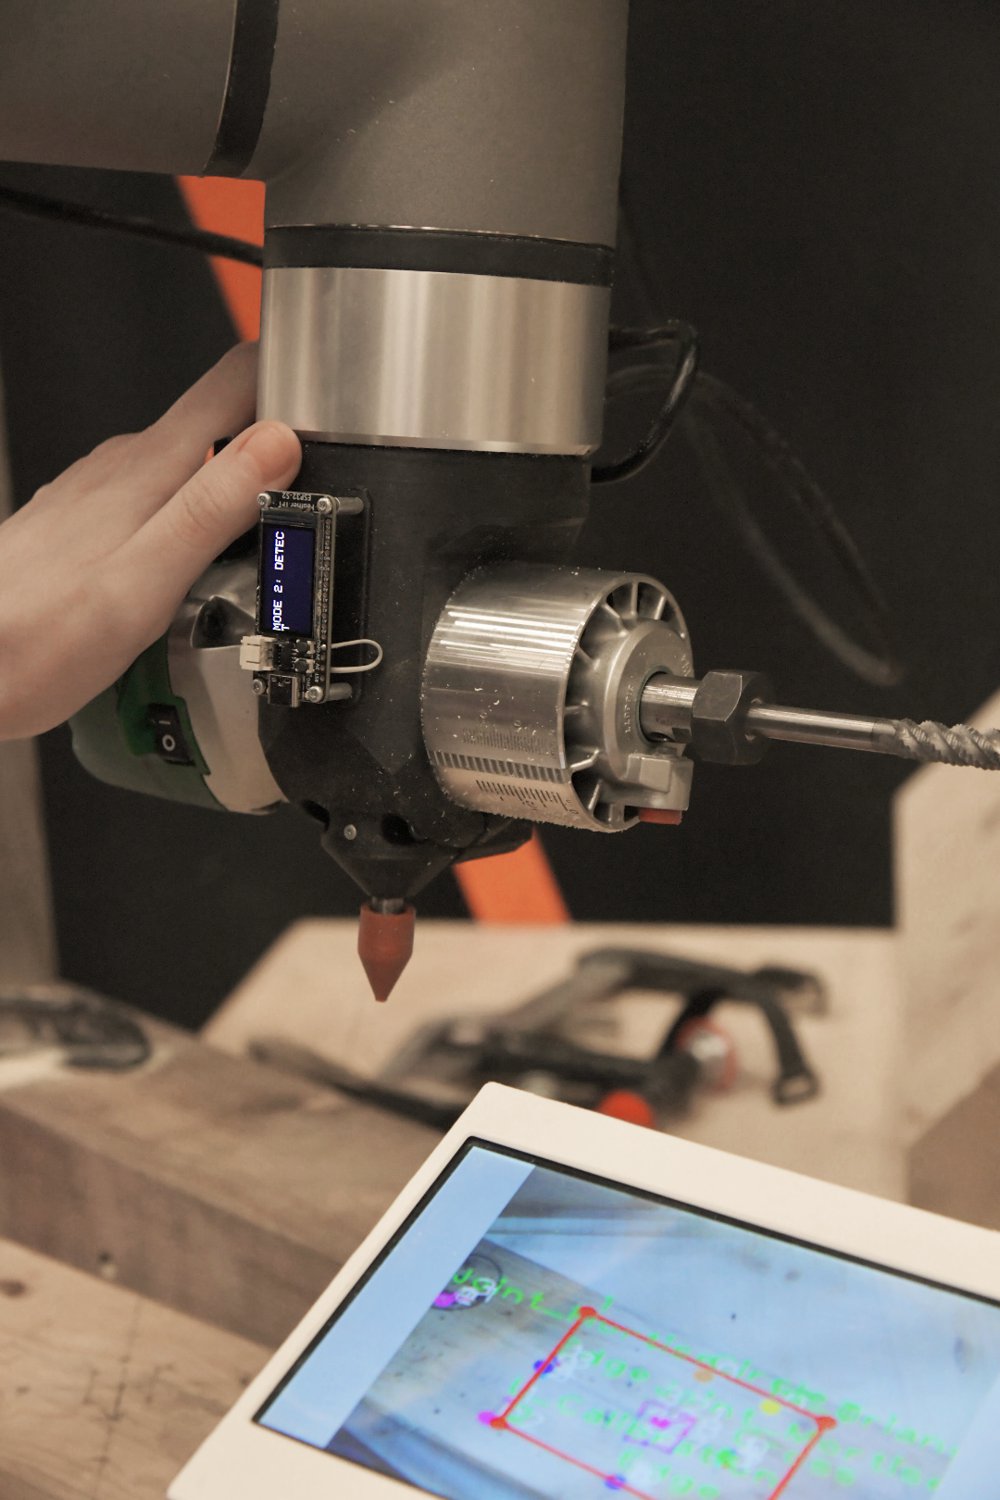
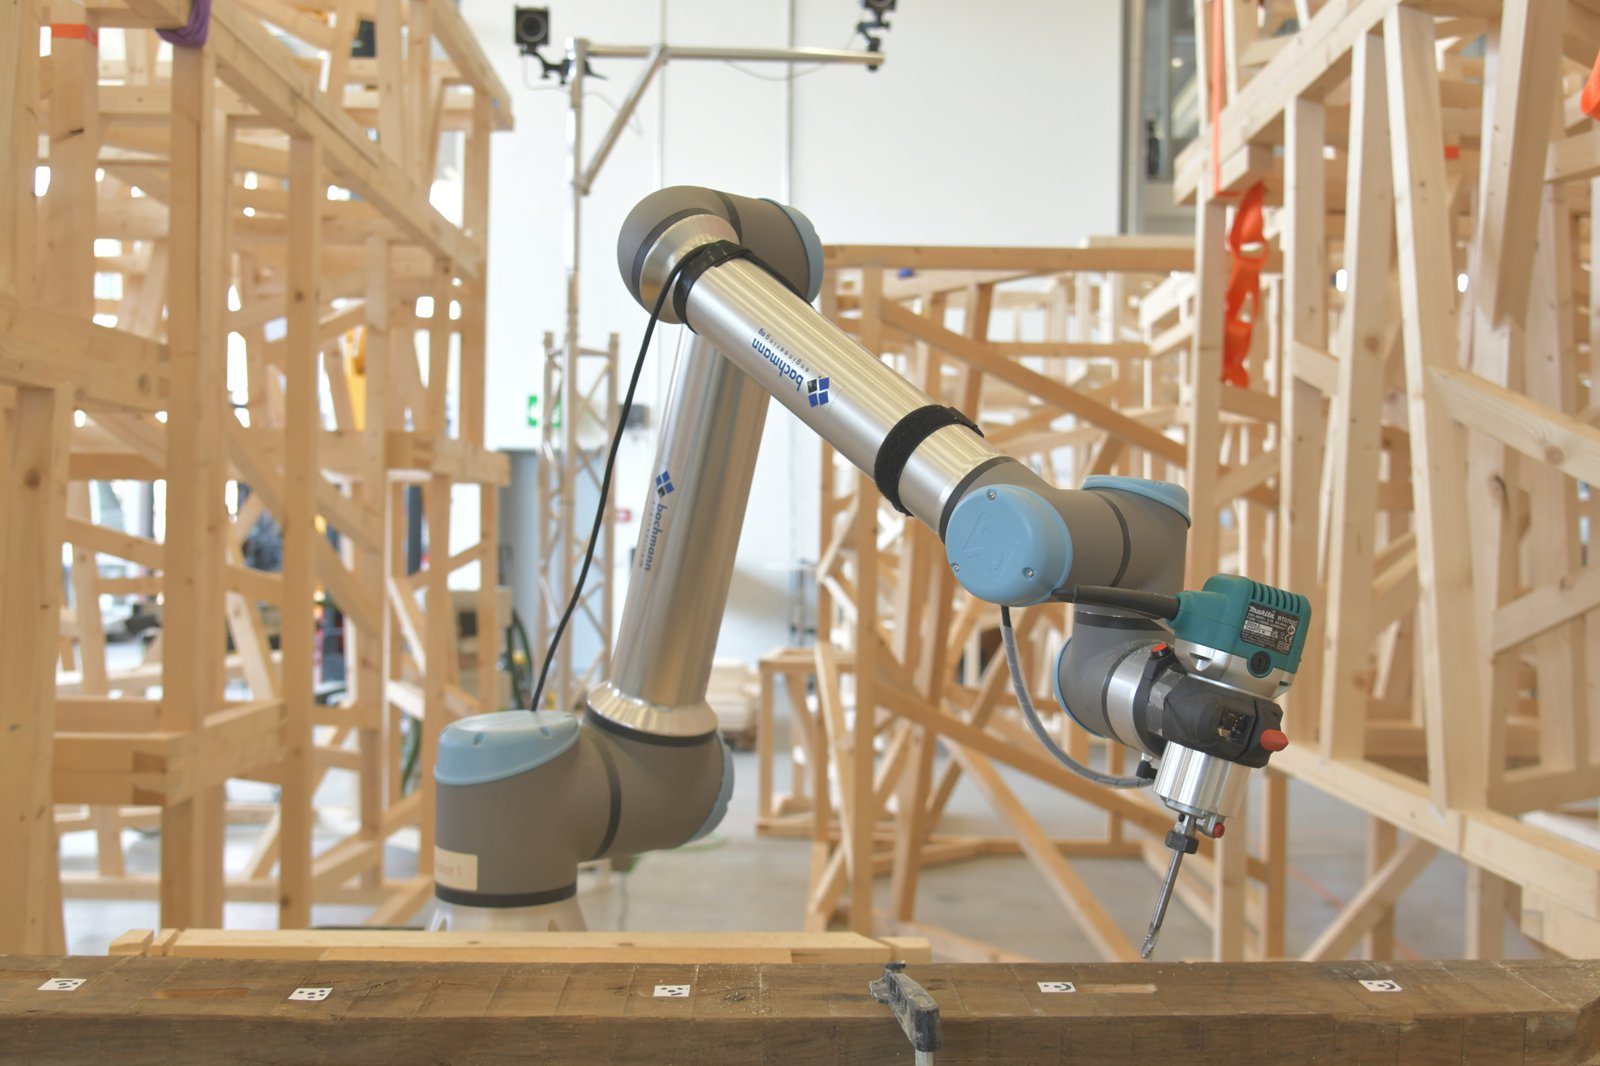
The carpenter draws the marking directly on the timber, as they would for a colleague. Using the push buttons on the end effector, they guide the robot over the marking; the camera captures it, and the detected symbol and its parameters appear on the touchscreen. Once confirmed, a toolpath is generated and the robot mills the feature with the router.
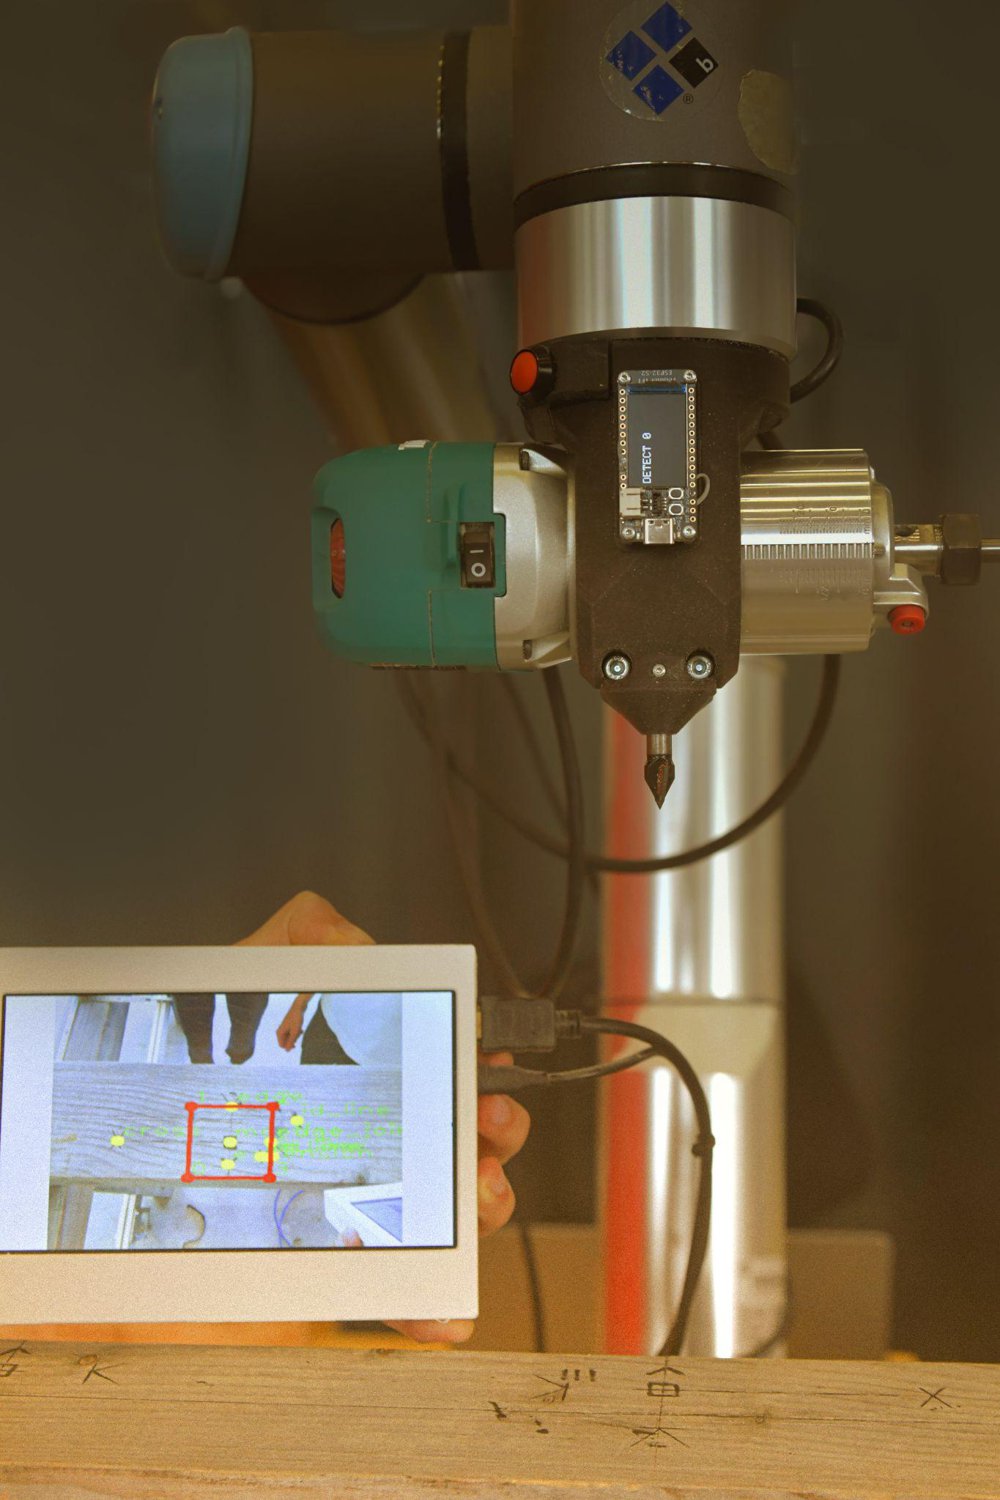
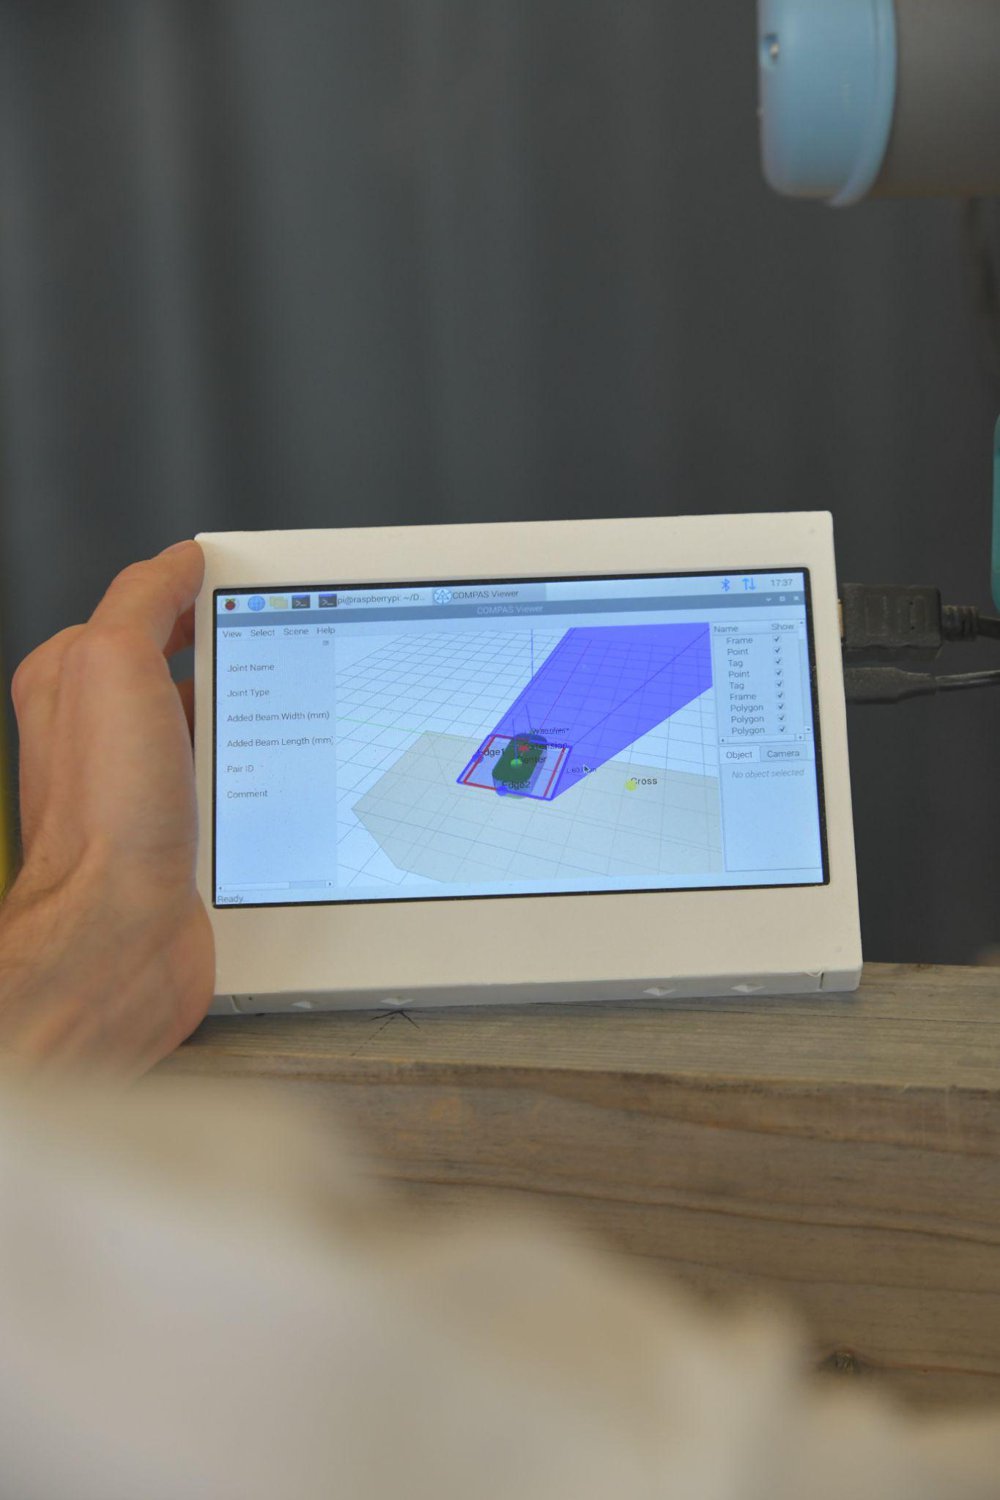
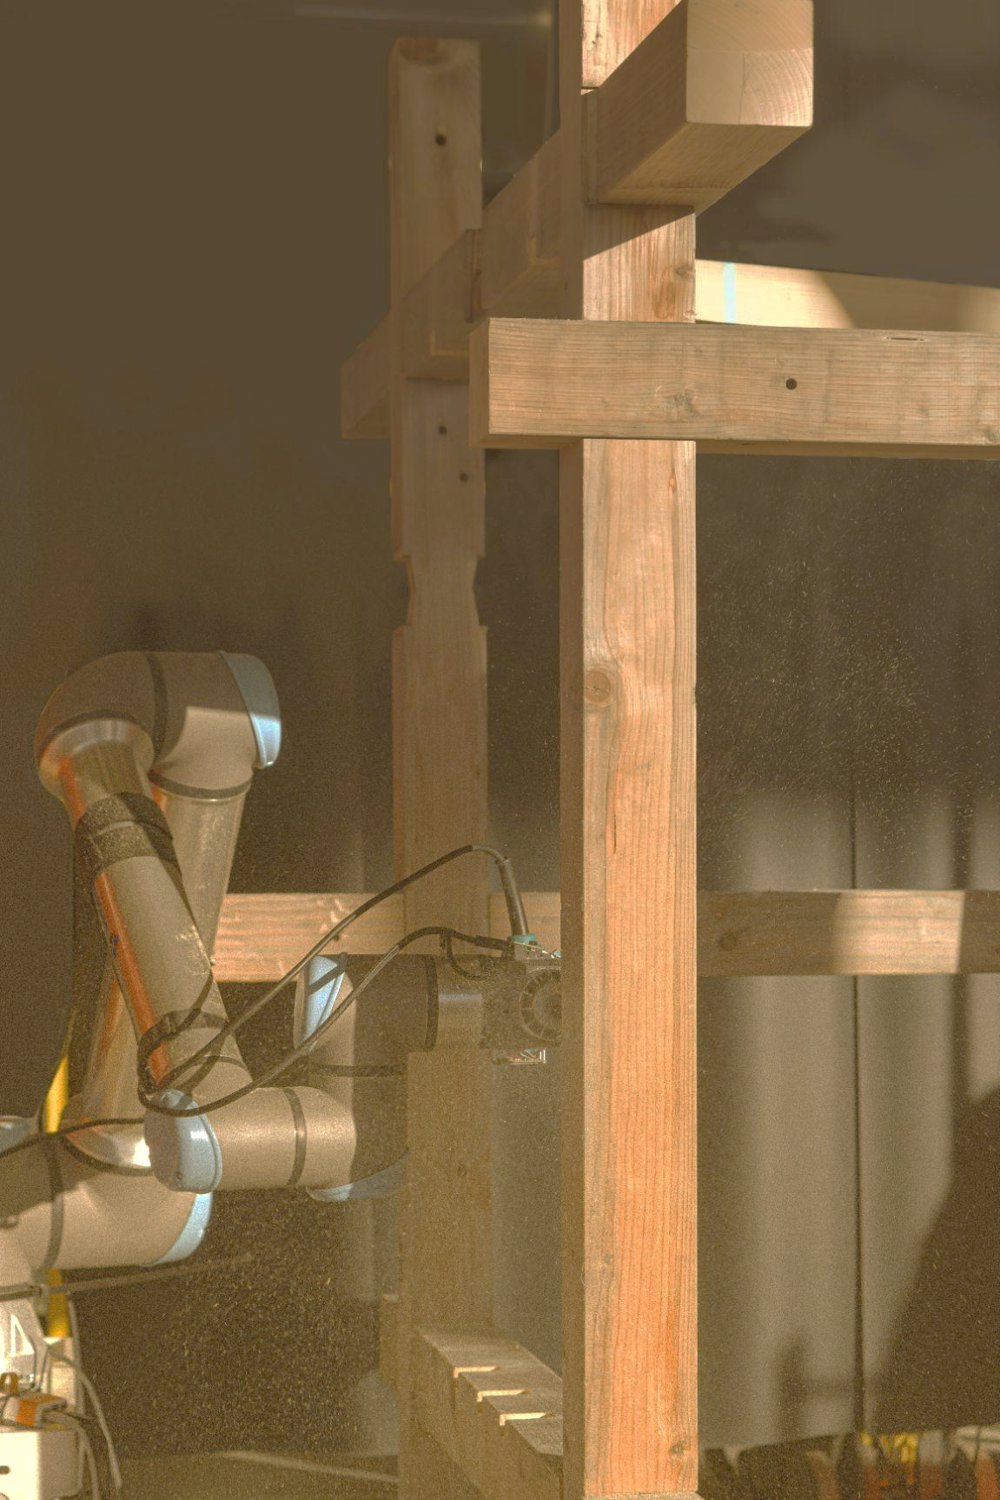
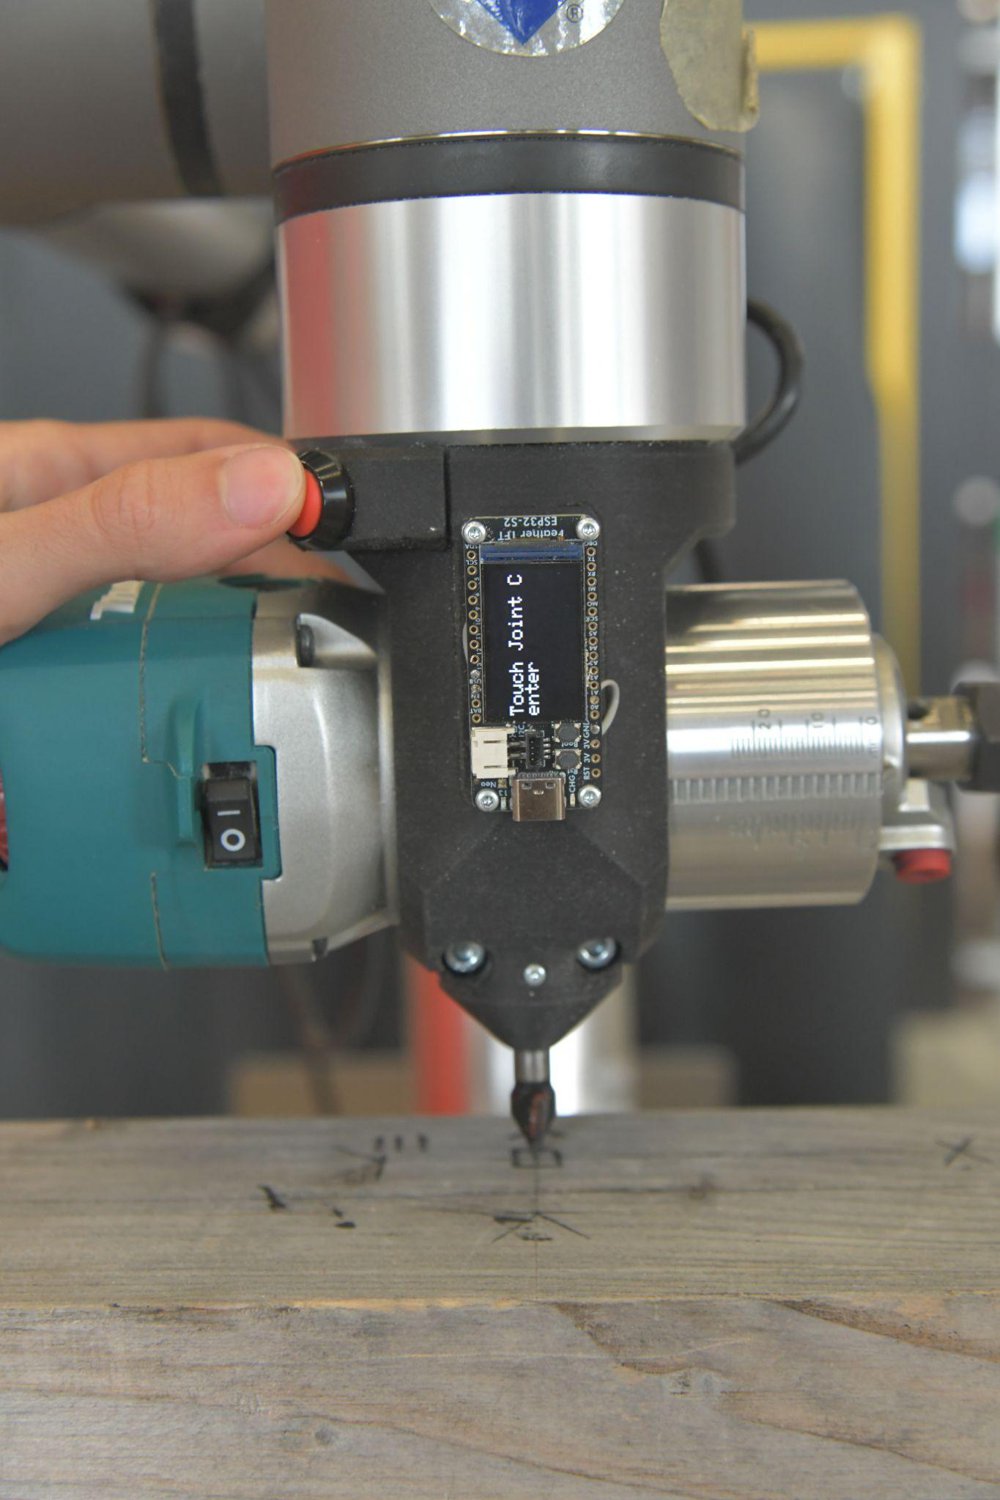
Before milling, each detection is checked against the timber, both on the camera image and in the digital model, and points can be touched up with the pin on the end effector for higher precision. In the joint-level experiment, mortises marked directly on the structure were milled in place, building up an on-site demonstrator with the robot working from four positions.
All rights reserved, ananya kango 2026